Conformal Policy Control
@inproceedings{prinster2026conformal,
  title = {Conformal Policy Control},
  author = {Prinster, Drew and Fannjiang, Clara and Park, Ji Won and Cho, Kyunghyun and Liu, Anqi and Saria, Suchi and Stanton, Samuel Don},
  booktitle = {Forty-third International Conference on Machine Learning},
  year = {2026},
  url = {https://arxiv.org/abs/2603.02196}
}
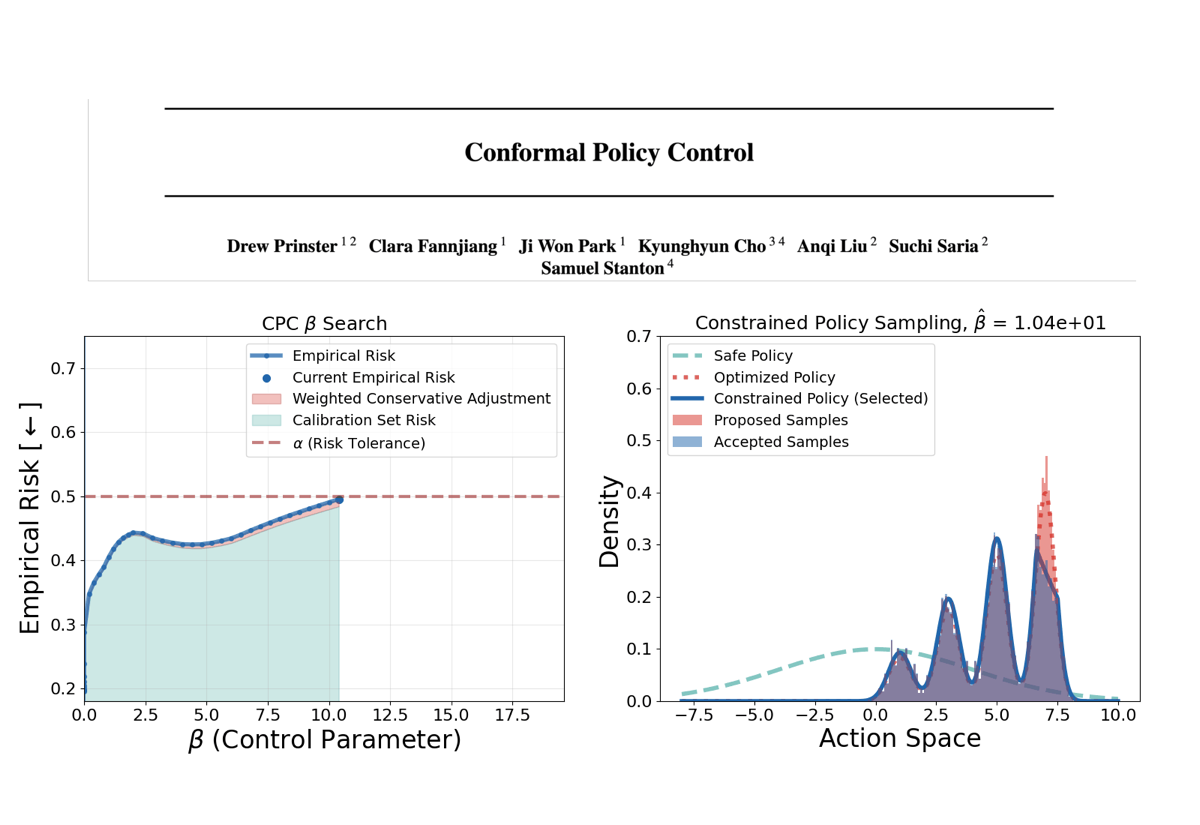
A framework to directly instruct an arbitrary AI agent on how far to advance its capabilities while still guaranteeing respect for user-specified safety constraints (e.g., safety violations <= 5%). The key requirements are access to any “safe policy” (e.g., a previous agent version verified to be safe) and any “optimized policy” (e.g., a new agent version trained for capabilities but not yet verified for safety). Conformal policy control (CPC) then searches “between” these policies to find an intermediate one that is optimized but guaranteed to respect the safety constraint. Experiments on applications ranging from medical question answering to biomolecular engineering show it is not only possible to safely advance AI abilities from the first moment of deployment, but that such safety can even counterintuitively improve performance.